HFSS knowledge graph
The problem
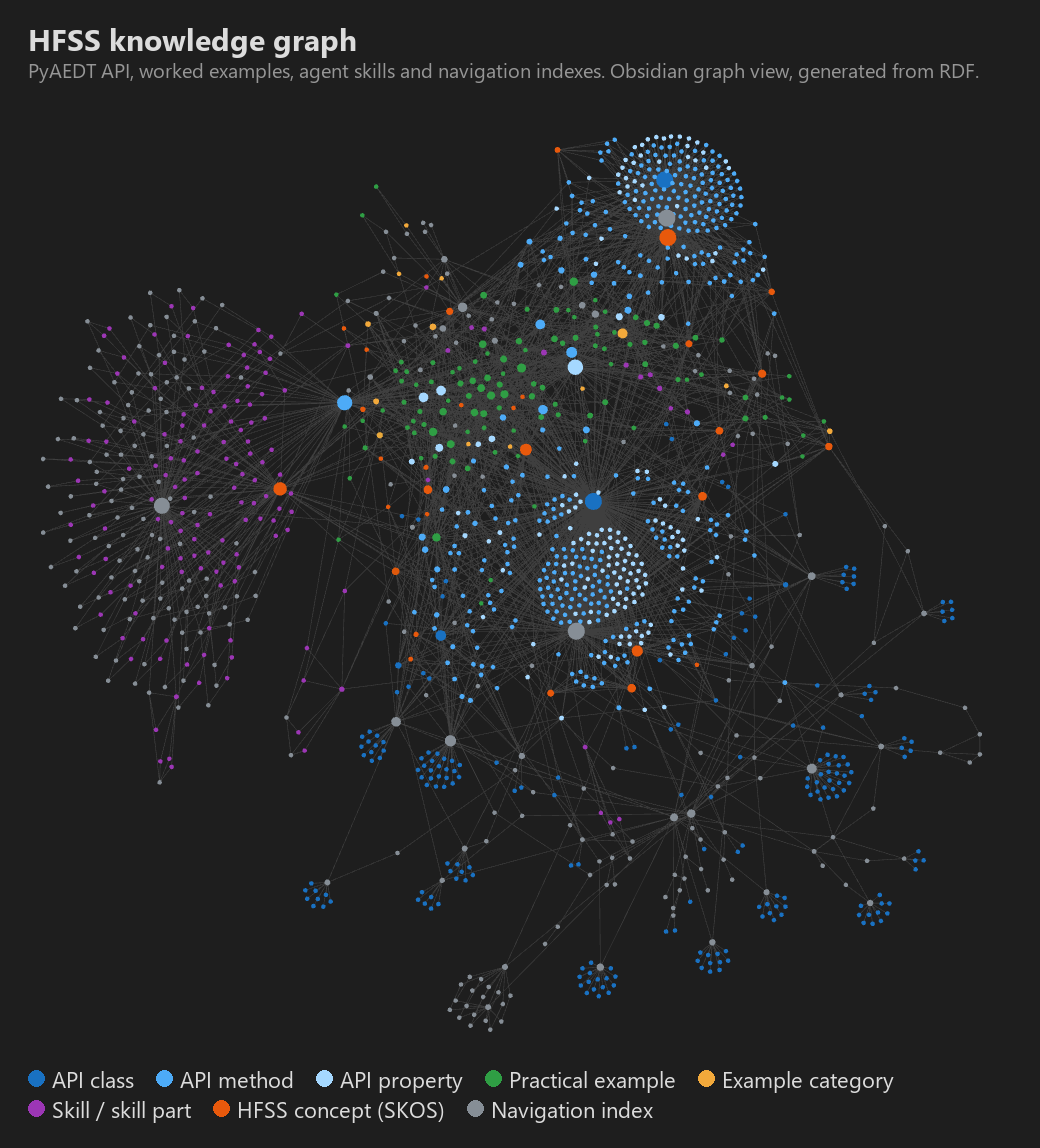
An agent that drives Ansys HFSS through PyAEDT has to find the right call before it can make it. The knowledge layer I wrote for one has three parts: a markdown mirror of the PyAEDT 0.18.1 API (4,151 documented methods and properties), 108 worked examples in 14 categories, and 48 agent skills. Index and map files route the agent from a topic to an example, or from a feature area to a class map to a method page. That routing was a graph already, but nothing could check it or ask it questions.
The ontology
I modelled it in OWL: 18 classes (API module, class, method, property; navigation index;
practical example and category; skill and skill reference; HFSS concept), 10 object properties
such as memberOf, indexes, inCategory, usesApi and returnsType, and a 30-concept SKOS
scheme for physics and workflow ideas like radiation boundaries, wave ports and frequency sweeps.
A Python builder (rdflib) walks the source read-only. It turns links and index tables into
navigation edges, and parses every example’s Python with ast to find the PyAEDT members it
really calls. The result is 52,732 triples: about 5,500 nodes and 18,855 edges, rebuilt in three
seconds.
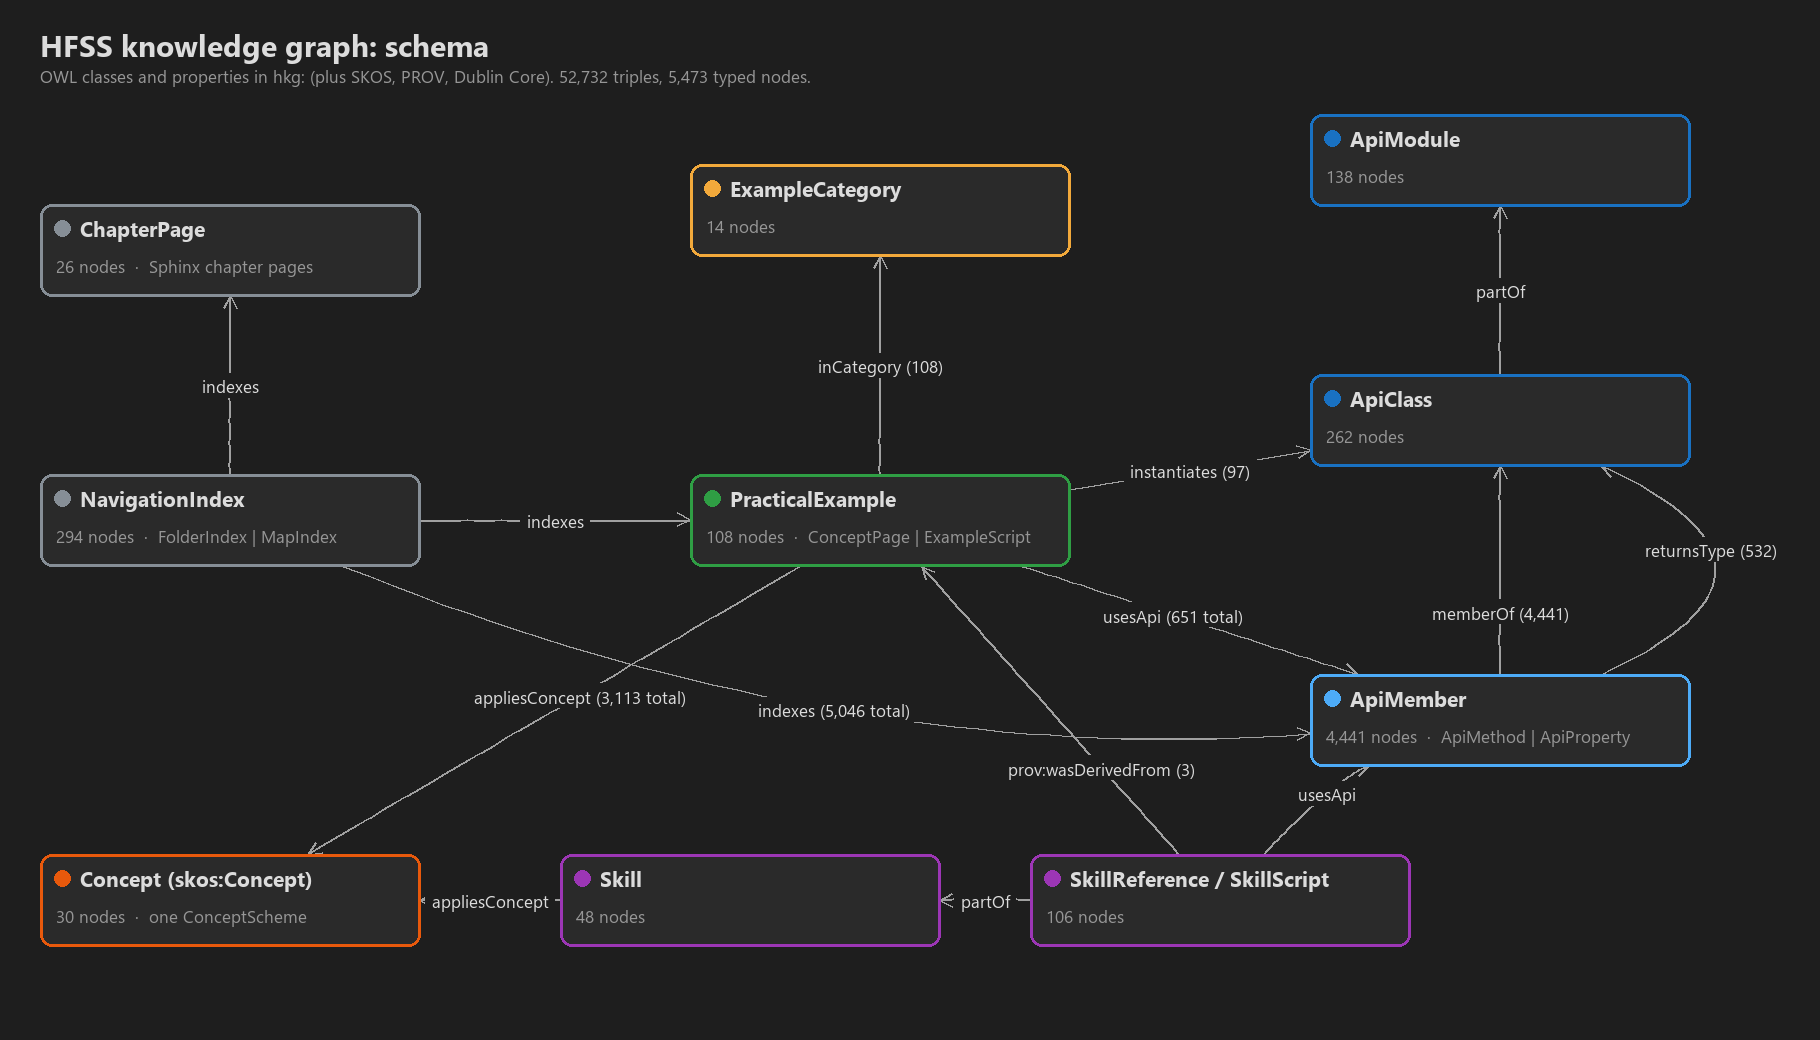 The schema: OWL classes and the properties between them, with node and edge counts.
SHACL checks
Seventeen SHACL shapes split problems three ways: modelling bugs (violations), defects in the source content (warnings), and coverage signals (info). The final graph has no violations. Along the way the shapes caught two bugs in my own builder, and I fixed both in the builder rather than loosening the shapes. The 48 warnings are real content findings: 2,813 broken links in ten per-application API maps, 25 indexes that lead nowhere, and one example that calls a method PyAEDT 0.18.1 doesn’t have.
Competency questions
Twelve SPARQL queries define what the graph has to answer. A few of them:
- Which examples demonstrate assigning a radiation boundary? 14 examples and one skill reference.
- Which HFSS methods does no example use? 315 of 399, so the examples cover 21%.
- Which index reaches
create_open_regionfastest? The class map, in one hop; from the root index it takes six. - Which categories overlap most? The canonical drivers and geometry share 25 API members.
- Which skill pages are verbatim copies of an example page? 3, recorded with
prov:wasDerivedFromso they don’t drift.
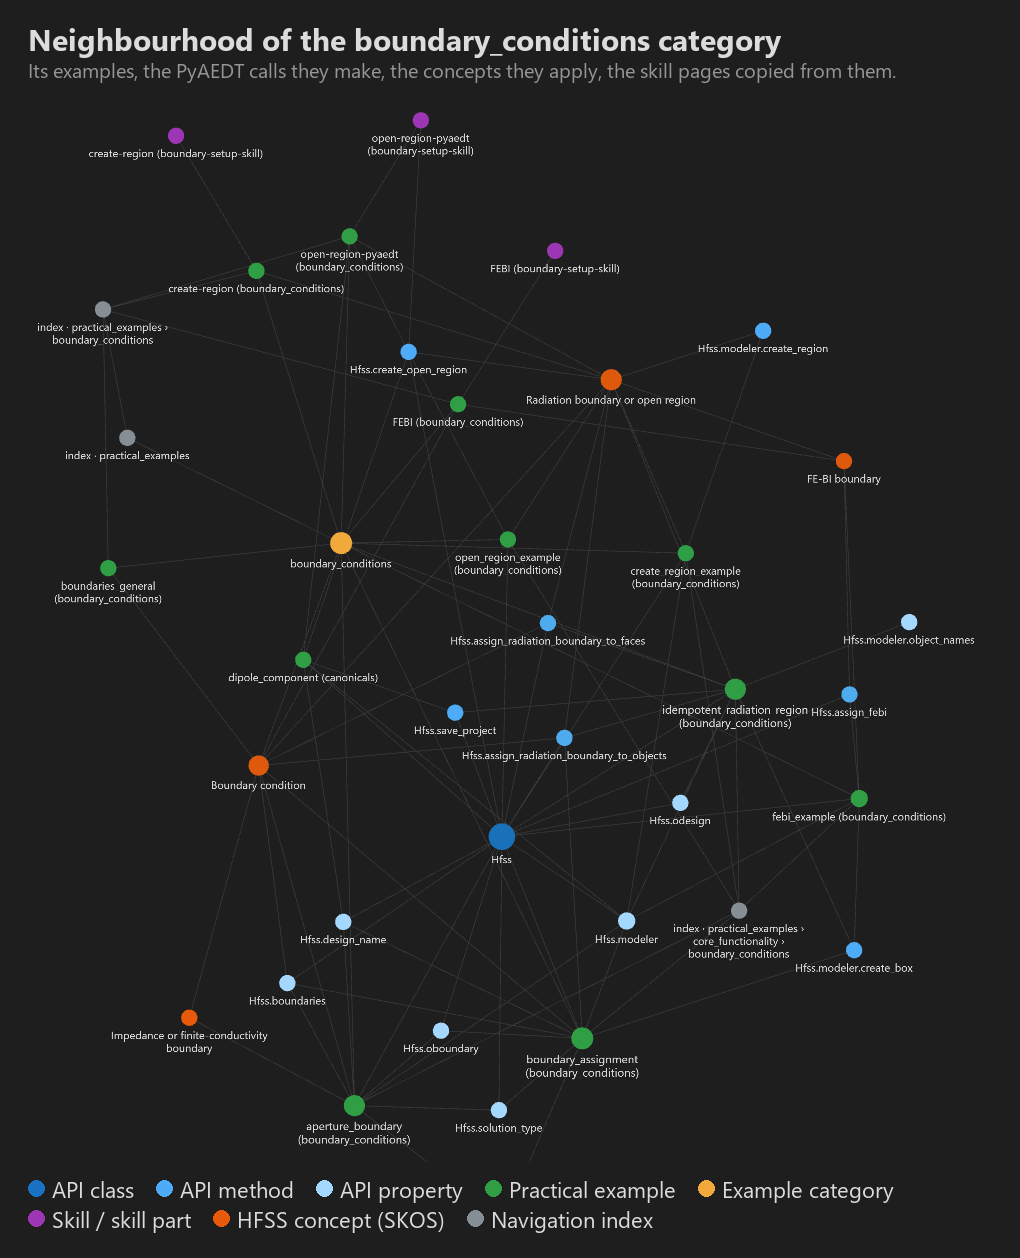 Two hops around the boundary_conditions category: its examples, the PyAEDT calls they make, the concepts they apply, and the skill pages copied from them.